#include <ROL_Constraint_SerialSimOpt.hpp>
Public Member Functions | |
| ~SlacklessObjective () | |
| SlacklessObjective (const Ptr< Objective< Real > > &obj) | |
| Ptr< Objective< Real > > | getObjective (void) const |
| void | update (const Vector< Real > &x, UpdateType type, int iter=-1) override |
| Update objective function. | |
| void | update (const Vector< Real > &x, bool flag=true, int iter=-1) override |
| Update objective function. | |
| Real | value (const Vector< Real > &x, Real &tol) override |
| Compute value. | |
| Real | dirDeriv (const Vector< Real > &x, const Vector< Real > &d, Real &tol) override |
| Compute directional derivative. | |
| void | gradient (Vector< Real > &g, const Vector< Real > &x, Real &tol) override |
| Compute gradient. | |
| void | hessVec (Vector< Real > &hv, const Vector< Real > &v, const Vector< Real > &x, Real &tol) override |
| Apply Hessian approximation to vector. | |
| void | invHessVec (Vector< Real > &ihv, const Vector< Real > &v, const Vector< Real > &x, Real &tol) override |
| Apply inverse Hessian approximation to vector. | |
| void | precond (Vector< Real > &Pv, const Vector< Real > &v, const Vector< Real > &x, Real &tol) override |
| Apply preconditioner to vector. | |
| void | setParameter (const std::vector< Real > ¶m) override |
| Public Member Functions inherited from ROL::ROL::Objective< Real > | |
| virtual | ~Objective () |
| Objective () | |
| virtual void | prox (Vector< Real > &Pv, const Vector< Real > &v, Real t, Real &tol) |
| Compute the proximity operator. | |
| virtual void | proxJacVec (Vector< Real > &Jv, const Vector< Real > &v, const Vector< Real > &x, Real t, Real &tol) |
| Apply the Jacobian of the proximity operator. | |
| virtual std::vector< std::vector< Real > > | checkGradient (const Vector< Real > &x, const Vector< Real > &d, const bool printToStream=true, std::ostream &outStream=std::cout, const int numSteps=ROL_NUM_CHECKDERIV_STEPS, const int order=1) |
| Finite-difference gradient check. | |
| virtual std::vector< std::vector< Real > > | checkGradient (const Vector< Real > &x, const Vector< Real > &g, const Vector< Real > &d, const bool printToStream=true, std::ostream &outStream=std::cout, const int numSteps=ROL_NUM_CHECKDERIV_STEPS, const int order=1) |
| Finite-difference gradient check. | |
| virtual std::vector< std::vector< Real > > | checkGradient (const Vector< Real > &x, const Vector< Real > &d, const std::vector< Real > &steps, const bool printToStream=true, std::ostream &outStream=std::cout, const int order=1) |
| Finite-difference gradient check with specified step sizes. | |
| virtual std::vector< std::vector< Real > > | checkGradient (const Vector< Real > &x, const Vector< Real > &g, const Vector< Real > &d, const std::vector< Real > &steps, const bool printToStream=true, std::ostream &outStream=std::cout, const int order=1) |
| Finite-difference gradient check with specified step sizes. | |
| virtual std::vector< std::vector< Real > > | checkHessVec (const Vector< Real > &x, const Vector< Real > &v, const bool printToStream=true, std::ostream &outStream=std::cout, const int numSteps=ROL_NUM_CHECKDERIV_STEPS, const int order=1) |
| Finite-difference Hessian-applied-to-vector check. | |
| virtual std::vector< std::vector< Real > > | checkHessVec (const Vector< Real > &x, const Vector< Real > &hv, const Vector< Real > &v, const bool printToStream=true, std::ostream &outStream=std::cout, const int numSteps=ROL_NUM_CHECKDERIV_STEPS, const int order=1) |
| Finite-difference Hessian-applied-to-vector check. | |
| virtual std::vector< std::vector< Real > > | checkHessVec (const Vector< Real > &x, const Vector< Real > &v, const std::vector< Real > &steps, const bool printToStream=true, std::ostream &outStream=std::cout, const int order=1) |
| Finite-difference Hessian-applied-to-vector check with specified step sizes. | |
| virtual std::vector< std::vector< Real > > | checkHessVec (const Vector< Real > &x, const Vector< Real > &hv, const Vector< Real > &v, const std::vector< Real > &steps, const bool printToStream=true, std::ostream &outStream=std::cout, const int order=1) |
| Finite-difference Hessian-applied-to-vector check with specified step sizes. | |
| virtual std::vector< Real > | checkHessSym (const Vector< Real > &x, const Vector< Real > &v, const Vector< Real > &w, const bool printToStream=true, std::ostream &outStream=std::cout) |
| Hessian symmetry check. | |
| virtual std::vector< Real > | checkHessSym (const Vector< Real > &x, const Vector< Real > &hv, const Vector< Real > &v, const Vector< Real > &w, const bool printToStream=true, std::ostream &outStream=std::cout) |
| Hessian symmetry check. | |
| virtual std::vector< std::vector< Real > > | checkProxJacVec (const Vector< Real > &x, const Vector< Real > &v, Real t=Real(1), bool printToStream=true, std::ostream &outStream=std::cout, int numSteps=ROL_NUM_CHECKDERIV_STEPS) |
| Finite-difference proximity operator Jacobian-applied-to-vector check. | |
Private Member Functions | |
| Ptr< Vector< Real > > | getOpt (Vector< Real > &xs) const |
| Ptr< const Vector< Real > > | getOpt (const Vector< Real > &xs) const |
| void | zeroSlack (Vector< Real > &x) const |
Private Attributes | |
| const Ptr< Objective< Real > > | obj_ |
Additional Inherited Members | |
| Protected Member Functions inherited from ROL::ROL::Objective< Real > | |
| const std::vector< Real > | getParameter (void) const |
Detailed Description
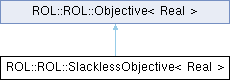
class ROL::ROL::SlacklessObjective< Real >
Definition at line 25 of file ROL_Constraint_SerialSimOpt.hpp.
Constructor & Destructor Documentation
◆ ~SlacklessObjective()
|
inline |
Definition at line 30 of file ROL_Constraint_SerialSimOpt.hpp.
◆ SlacklessObjective()
| ROL::ROL::SlacklessObjective< Real >::SlacklessObjective | ( | const Ptr< Objective< Real > > & | obj | ) |
Definition at line 16 of file ROL_SlacklessObjective_Def.hpp.
References obj_, and ROL::ROL::Objective< Real >::Objective().
Member Function Documentation
◆ getObjective()
| Ptr< Objective< Real > > ROL::ROL::SlacklessObjective< Real >::getObjective | ( | void | ) | const |
Definition at line 19 of file ROL_SlacklessObjective_Def.hpp.
References obj_.
◆ update() [1/2]
|
overridevirtual |
Update objective function.
This function updates the objective function at new iterations.
- Parameters
-
[in] x is the new iterate. [in] type is the type of update requested. [in] iter is the outer algorithm iterations count.
Reimplemented from ROL::ROL::Objective< Real >.
Definition at line 24 of file ROL_SlacklessObjective_Def.hpp.
◆ update() [2/2]
|
overridevirtual |
Update objective function.
This function updates the objective function at new iterations.
- Parameters
-
[in] x is the new iterate. [in] flag is true if the iterate has changed. [in] iter is the outer algorithm iterations count.
Reimplemented from ROL::ROL::Objective< Real >.
Definition at line 29 of file ROL_SlacklessObjective_Def.hpp.
◆ value()
|
overridevirtual |
Compute value.
This function returns the objective function value.
- Parameters
-
[in] x is the current iterate. [in] tol is a tolerance for inexact objective function computation.
Implements ROL::ROL::Objective< Real >.
Definition at line 34 of file ROL_SlacklessObjective_Def.hpp.
◆ dirDeriv()
|
overridevirtual |
Compute directional derivative.
This function returns the directional derivative of the objective function in the \(d\) direction.
- Parameters
-
[in] x is the current iterate. [in] d is the direction. [in] tol is a tolerance for inexact objective function computation.
Reimplemented from ROL::ROL::Objective< Real >.
Definition at line 39 of file ROL_SlacklessObjective_Def.hpp.
◆ gradient()
|
overridevirtual |
Compute gradient.
This function returns the objective function gradient.
- Parameters
-
[out] g is the gradient. [in] x is the current iterate. [in] tol is a tolerance for inexact objective function computation.
The default implementation is a finite-difference approximation based on the function value. This requires the definition of a basis \(\{\phi_i\}\) for the optimization vectors x and the definition of a basis \(\{\psi_j\}\) for the dual optimization vectors (gradient vectors g). The bases must be related through the Riesz map, i.e., \( R \{\phi_i\} = \{\psi_j\}\), and this must be reflected in the implementation of the ROL::Vector::dual() method.
Reimplemented from ROL::ROL::Objective< Real >.
Definition at line 44 of file ROL_SlacklessObjective_Def.hpp.
References getOpt(), obj_, and zeroSlack().
◆ hessVec()
|
overridevirtual |
Apply Hessian approximation to vector.
This function applies the Hessian of the objective function to the vector \(v\).
- Parameters
-
[out] hv is the the action of the Hessian on \(v\). [in] v is the direction vector. [in] x is the current iterate. [in] tol is a tolerance for inexact objective function computation.
Reimplemented from ROL::ROL::Objective< Real >.
Definition at line 50 of file ROL_SlacklessObjective_Def.hpp.
References getOpt(), obj_, and zeroSlack().
◆ invHessVec()
|
overridevirtual |
Apply inverse Hessian approximation to vector.
This function applies the inverse Hessian of the objective function to the vector \(v\).
- Parameters
-
[out] hv is the action of the inverse Hessian on \(v\). [in] v is the direction vector. [in] x is the current iterate. [in] tol is a tolerance for inexact objective function computation.
Reimplemented from ROL::ROL::Objective< Real >.
Definition at line 56 of file ROL_SlacklessObjective_Def.hpp.
References ROL::ROL::PartitionedVector< Real >::get(), getOpt(), ROL::ROL::PartitionedVector< Real >::numVectors(), and obj_.
◆ precond()
|
overridevirtual |
Apply preconditioner to vector.
This function applies a preconditioner for the Hessian of the objective function to the vector \(v\).
- Parameters
-
[out] Pv is the action of the Hessian preconditioner on \(v\). [in] v is the direction vector. [in] x is the current iterate. [in] tol is a tolerance for inexact objective function computation.
Reimplemented from ROL::ROL::Objective< Real >.
Definition at line 67 of file ROL_SlacklessObjective_Def.hpp.
References ROL::ROL::PartitionedVector< Real >::get(), getOpt(), ROL::ROL::PartitionedVector< Real >::numVectors(), and obj_.
◆ setParameter()
|
overridevirtual |
Reimplemented from ROL::ROL::Objective< Real >.
Definition at line 78 of file ROL_SlacklessObjective_Def.hpp.
References obj_, and ROL::Objective< Real >::setParameter().
◆ getOpt() [1/2]
|
private |
Definition at line 84 of file ROL_SlacklessObjective_Def.hpp.
Referenced by dirDeriv(), gradient(), hessVec(), invHessVec(), precond(), update(), update(), and value().
◆ getOpt() [2/2]
|
private |
Definition at line 89 of file ROL_SlacklessObjective_Def.hpp.
◆ zeroSlack()
|
private |
Definition at line 94 of file ROL_SlacklessObjective_Def.hpp.
References ROL::ROL::PartitionedVector< Real >::get(), and ROL::ROL::PartitionedVector< Real >::numVectors().
Referenced by gradient(), and hessVec().
Member Data Documentation
◆ obj_
|
private |
Definition at line 27 of file ROL_Constraint_SerialSimOpt.hpp.
Referenced by dirDeriv(), getObjective(), gradient(), hessVec(), invHessVec(), precond(), setParameter(), SlacklessObjective(), update(), update(), and value().
The documentation for this class was generated from the following files:
Generated by
 1.15.0